Some engineering ideas are so elegant they make you want to slow-clap in the lab. The harmonic drive is one of them. It takes a clever bit of elastic deformation, mixes in precision gearing, and produces a transmission that can deliver high torque from a surprisingly compact package. That is already impressive. But engineers and makers, being the wonderfully restless people they are, keep asking the same question: can this thing get even slimmer?
That question sits at the heart of the idea behind a harmonic drive that uses a compliant mechanism to slim down. Instead of relying only on a conventional rigid assembly with more bulk, designers explore flexible members, integrated motion features, and low-part-count geometry to reduce size, shave weight, and simplify the package. It is the mechanical equivalent of switching from a bulky winter coat to a tailored jacket without freezing on the sidewalk.
The result is not just a smaller gearbox. It is a different way of thinking about motion control. A compliant mechanism does not always need pins, hinges, and a parade of extra parts to move. It can bend, flex, and store energy in the material itself. When applied to harmonic-drive-style systems, that approach can open the door to compact robotic joints, lighter end effectors, more efficient layouts, and creative manufacturing methods that were hard to imagine a decade ago.
Still, this is engineering, not magic. Slimmer does not automatically mean better. A thinner, lighter design has to wrestle with stiffness, fatigue, friction, heat, wear, manufacturing tolerances, and material choice. So the real story is not “make it smaller and call it a day.” The real story is how a compliant mechanism can help a harmonic drive become leaner while preserving the precision and torque that made strain-wave gearing famous in the first place.
What a harmonic drive actually does
Before we talk about slimming one down, it helps to understand why harmonic drives matter. A harmonic drive, often called a strain-wave gear, typically uses three main elements: a wave generator, a flexspline, and a circular spline. The wave generator deforms the flexspline into an elliptical shape, which makes the teeth mesh with the circular spline at opposing regions. Because the tooth counts are slightly different, the flexspline rotates by a small amount relative to the outer spline with each input rotation. That tiny mismatch is the secret sauce behind the large reduction ratio.
In plain English, a harmonic drive lets a fast motor spin into slower, more forceful, more controllable motion. That is why these drives show up in robotics, automation, aerospace, medical devices, semiconductor equipment, and other applications where positional accuracy, compact packaging, and low backlash are worth their weight in gold. In some designs, the size and weight stay impressively restrained even when the reduction ratio climbs, which is why engineers keep coming back to the architecture.
There is also a reason robotic designers love the concept. Joints on robot arms, mobile platforms, and collaborative systems all compete for the same precious resources: space, mass, stiffness, and accuracy. A gearbox that can provide high reduction in a compact form factor is like getting extra seating on a full flight. Nobody complains.
Why compliant mechanisms are such a tempting upgrade
A compliant mechanism achieves motion through elastic deformation rather than through many discrete moving joints. That sounds simple, but the implications are huge. A compliant feature can reduce part count, eliminate some interfaces, cut friction in certain locations, simplify assembly, and make a mechanism easier to miniaturize. It can also improve packaging because the motion is embedded into the shape of the structure itself rather than bolted on afterward.
That is exactly why compliant design is attractive in a harmonic-drive-inspired transmission. Traditional strain-wave gearing already relies on elastic behavior in the flexspline. In other words, compliance is not a weird outsider crashing the party. It is already on the guest list. The real innovation is using compliant members more deliberately so the drive can become flatter, lighter, or less dependent on bulky supporting geometry.
Think of it this way: conventional mechanisms often say, “Here are the parts that move.” Compliant mechanisms say, “What if the structure itself becomes the motion?” When that mindset is applied well, it can replace separate springs, reduce hardware, shrink the envelope, and produce a cleaner mechanical path from motor input to controlled output.
How a compliant harmonic drive can slim down the package
1. It can reduce bulky support geometry
One route to a slimmer drive is replacing some conventional jointed features with flexure-like elements or integrated spring geometry. If a designer can build compliance directly into the structure, the assembly may need fewer separate supports, less housing volume, or fewer stacked components. That matters in compact robotic joints where every millimeter has to earn its keep.
2. It can lower part count
Fewer parts usually means fewer interfaces, fewer tolerance stack-ups, and fewer opportunities for assembly headaches. Anyone who has ever dropped a tiny fastener into a machine frame and then spent twenty minutes fishing for it knows this is not a trivial benefit. In a compact transmission, integrating motion and elasticity into fewer components can make the design cleaner and easier to manufacture at small scales.
3. It can improve layout freedom
Compliant structures can be shaped in creative ways, especially when additive manufacturing or advanced machining is available. This gives designers more freedom to tuck motion features into unused volumes, slim the profile, or tailor stiffness only where it is needed. That kind of geometry freedom is especially useful in robotics, where motors, sensors, bearings, cable routing, and thermal management all compete inside tight envelopes.
4. It can help lightweight applications
Weight reduction is not just about bragging rights on a spec sheet. In robotics, lower mass can improve acceleration, reduce energy use, shrink motor requirements, and lessen inertia at the end of an arm. A lighter transmission can also help collaborative robots and mobile systems that need good performance without carrying a mechanical backpack full of unnecessary metal.
The catch: slimmer designs have to survive the real world
If the story ended there, every gearbox on Earth would already be on a diet. But slimming a harmonic drive through compliant design introduces tradeoffs that are impossible to ignore.
Fatigue is the loudest skeptic in the room
Compliance means repeated elastic deformation. Repeated deformation means stress cycling. Stress cycling eventually turns into fatigue risk if the material, geometry, or loading conditions are not carefully designed. In a strain-wave transmission, the flexing element is already doing real work. Asking it to do more while also getting thinner is not something you do with fingers crossed and a motivational poster.
Stiffness can become the deal-breaker
Many precision motion systems do not just need reduction ratio. They need torsional stiffness, repeatability, and predictable control behavior. If a slimmed-down compliant architecture becomes too soft, the transmission may introduce unwanted deflection, hysteresis, or control headaches. That is one reason harmonic-drive modeling often pays close attention to nonlinear stiffness, friction, and hysteresis instead of pretending the gearbox is a perfectly obedient little angel.
Material choice matters more than ever
A compliant mechanism lives or dies by material behavior. An early prototype might work beautifully in a demonstration and then complain loudly under load, heat, or repeated cycles. That is why material upgrades are such a big part of the modern story. Engineers are exploring better steels, specialized manufacturing routes, and even advanced metal-forming or additive techniques to build thin flexing parts that are wear-resistant where they need tooth durability and fracture-resistant where they need survivability.
Efficiency and friction still matter
Compact precision drives are wonderful, but they are not immune to losses. In robotic systems, gearing can contribute noticeably to heat and power loss. If a slim drive lowers bulk but creates new friction problems, then the “weight loss” comes with a mechanical junk-food problem. Good design has to balance compactness with smooth meshing, lubrication strategy, thermal behavior, and surface durability.
Why this idea makes so much sense for robotics
Robotics is arguably the perfect home for a slimmed-down harmonic drive. Precision joints crave low backlash, compact packaging, and strong torque density. At the same time, robot builders are always trying to reduce mass, simplify integration, and make joints easier to package with motors, bearings, encoders, and cables.
That is why strain-wave gearing has such a strong reputation in robot arms and precision motion systems. It is also why lightweight variants and ultra-compact gearheads keep appearing in the market. The smaller and lighter the joint, the easier it becomes to improve dynamic response, reduce motor burden, and free space for everything else the robot needs to function. A compliant mechanism approach fits naturally into that mission because it aims to preserve motion quality while trimming mechanical bulk.
There is even a broader historical angle here. Strain-wave gearing has been tied to demanding applications for decades, including space and rover systems. That does not mean every new compliant version is automatically space-ready, of course. It does mean the underlying architecture has long been trusted where compact, high-precision power transmission matters.
Prototypes are where the truth shows up uninvited
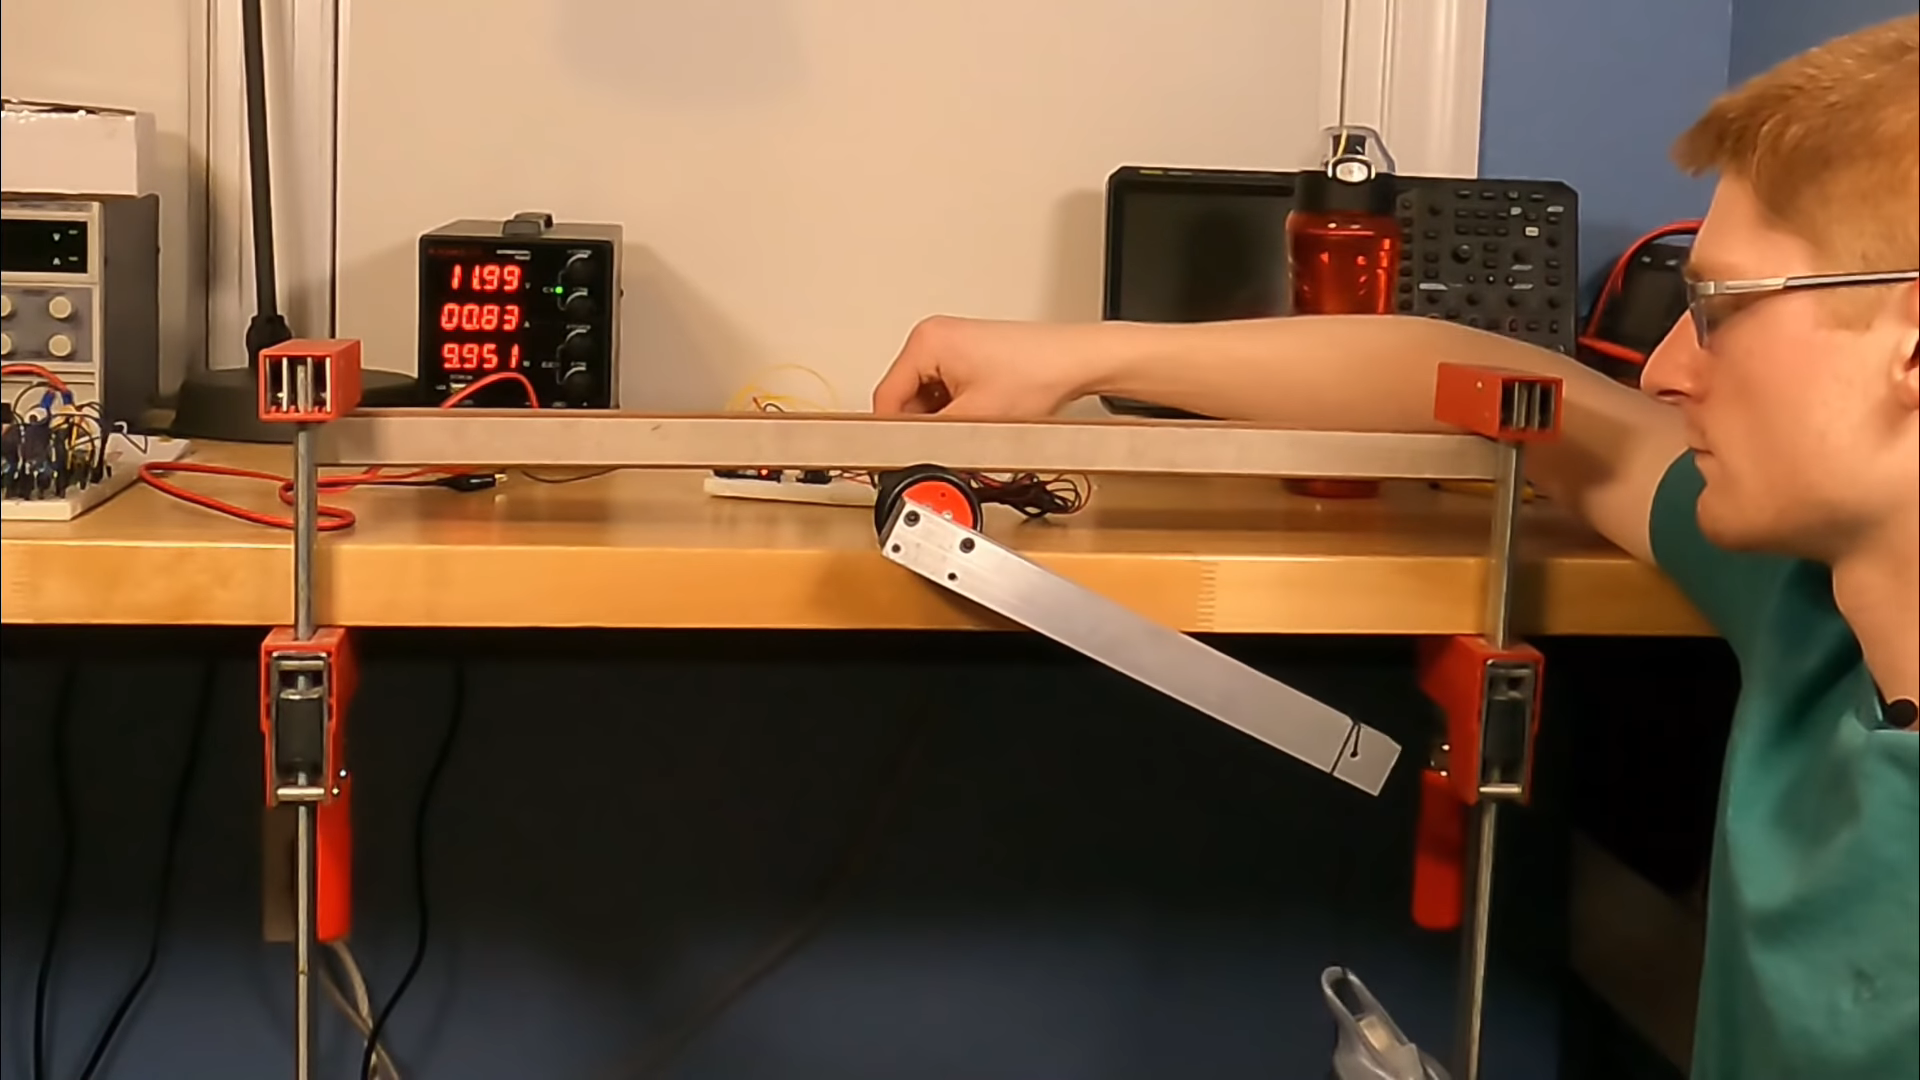
The maker and research worlds are full of experiments that prove a concept is possible before industry decides whether it is practical. A well-known example in the hobby engineering scene explored a 3D-printed compliant harmonic drive meant to create a more compact design. It showed the appeal of the idea immediately: clever geometry, integrated compliance, and a slimmer take on a famous transmission. It also showed the limitations just as quickly. Under light loads, polymer spring elements could begin to complain, which is a polite way of saying the prototype reminded everyone that material selection is not optional.
And honestly, that is not failure. That is engineering doing its job. Prototypes are supposed to reveal where the pretty concept collides with material science, fatigue limits, and practical torque transmission. Every crunching sound, every small deformation, every hot spot, and every tooth-wear pattern is useful information. It is the machine’s way of filing a very honest bug report.
New manufacturing methods are changing the conversation
One reason the “slim down” idea feels more realistic now is that manufacturing technology is catching up to design ambition. Additive approaches are being explored for flexsplines and related strain-wave components, including methods aimed at printing the thin wall, output features, and gear teeth as an integrated metal structure. That is important because conventional flexspline production can be demanding, and the thinner the feature, the less forgiving the process becomes.
Advanced materials add another layer of opportunity. Work tied to NASA and Caltech has pointed toward metallic-glass-based solutions and additive methods that could reduce cost, support thin flexible components, and improve wear or fracture performance in different regions of the part. The big promise is not that a single miracle material will solve everything. The promise is that engineers can increasingly tailor the flexing section, tooth region, and overall geometry with more nuance than before.
That is where compliant harmonic-drive concepts get especially interesting. Once you can shape geometry more freely and tune material behavior more deliberately, slimming down no longer means blindly making everything thinner. It means strategically putting stiffness, flexibility, durability, and weight exactly where they belong.
Will compliant harmonic drives replace every gearbox?
No, and that is perfectly fine. Mechanical engineering is not a reality show where one transmission gets voted off the island. Planetary systems, cycloidal drives, direct-drive actuators, and other architectures all keep their seats at the table because different jobs demand different compromises.
What a compliant harmonic-drive approach offers is a sharper option for applications that care deeply about compactness, precision, and system integration. It is especially compelling where the designer wants a flatter package, fewer components, or a custom geometry that a more conventional reducer struggles to provide. But it still requires careful control of stress, stiffness, and manufacturing quality. In short, it is a powerful design strategy, not a magic coupon for free performance.
Practical design lessons for engineers
If you are evaluating this concept seriously, a few lessons stand out. First, never treat compliance as “just a bendy part.” In a precision transmission, compliance is the mechanism. Second, build the design around fatigue life from the start rather than checking it at the end like an afterthought. Third, consider control behavior early, because backlash may be low while hysteresis and stiffness effects still shape system performance. Fourth, do not obsess over shaving grams while ignoring heat, lubrication, and wear. Fifth, prototype aggressively, because a beautiful CAD model has never once transmitted real torque by itself.
That last point deserves extra respect. Compact, compliant transmission design is one of those fields where the first prototype teaches humility, the second teaches patience, and the third starts to earn trust.
Experience section: what designers learn when they try to build one
Talk to people who have experimented with compact strain-wave drives, and a pattern shows up quickly. The first experience is usually delight. You spin the input, watch the output creep with that unmistakable high-reduction behavior, and suddenly a famously sophisticated mechanism feels approachable. It is one of those mechanical moments that makes people grin like they have just taught a toaster to do calculus.
Then reality arrives with steel-toed boots. A design that looks wonderfully slim on screen may reveal that the compliant region is too soft, the tooth engagement is not consistent enough, or the material does not like repeated flexing nearly as much as the simulation suggested. That does not mean the concept is wrong. It means the concept has moved from theory into adulthood.
One common experience is learning that compactness magnifies everything. Small errors in tooth form, slight eccentricity in the wave generator, modest printing defects, or tiny alignment issues can all show up in the motion. In a bulkier system, some of those sins hide in the crowd. In a slim compliant transmission, they step forward and introduce themselves.
Another lesson is that sound tells stories. A good prototype often feels smooth, with a controlled resistance that suggests the elastic elements and gear engagement are sharing the workload properly. A bad one develops clicking, grinding, squeaking, or that dreadful crunchy protest that says, “Hello, I am permanent deformation, and I live here now.” Builders quickly learn to respect the soundtrack of a mechanism. Silence is wonderful. Smooth humming is good. Crunching is the mechanical equivalent of a smoke alarm.
There is also a valuable emotional rhythm to these projects. Early frustration is normal. You make one part thicker and the mechanism survives but loses the slim elegance you wanted. You make it thinner and the packaging looks fantastic, but the stiffness falls off a cliff. You switch materials, adjust geometry, change tooth engagement, tune the compliant section, and repeat. The process can feel like arguing with a very smart machine that only answers in stress plots.
But when the design starts working, the reward is substantial. A successful slimmed-down harmonic-drive concept feels efficient in a way that is deeply satisfying. The parts look like they belong together. The transmission feels intentional. The motion is precise, compact, and a little bit sneaky, as though the mechanism is quietly doing more than its size should allow. That is the beauty of compliant design at its best: not complexity for its own sake, but elegance through purposeful flexibility.
Perhaps the most important experience, though, is learning restraint. Engineers often begin these projects wanting the smallest, lightest, cleverest possible result. Over time, many realize the real win is balance. The best design is not the thinnest flexure or the flashiest geometry. It is the one that delivers the needed torque, survives the duty cycle, behaves predictably in control, and still fits the package. In other words, the mature version of “slim down” is not dieting for the mirror. It is training for performance.
Conclusion
Harmonic drives were already a brilliant use of controlled flexibility. Adding a compliant-mechanism mindset takes that original brilliance and pushes it toward a new goal: even smaller, lighter, cleaner motion systems. Done well, the approach can reduce part count, shrink packaging, and support the relentless demand for compact precision in robotics and advanced automation. Done poorly, it can invite fatigue, softness, wear, and control trouble to dinner.
That tension is exactly what makes the idea interesting. “Harmonic Drive Uses Compliant Mechanism To Slim Down” is not just a catchy headline. It describes a real engineering direction where elasticity is no longer something to tolerate, but something to design on purpose. And when that purpose is backed by smart materials, careful modeling, and honest prototyping, the result can be more than slim. It can be seriously capable.